Projects
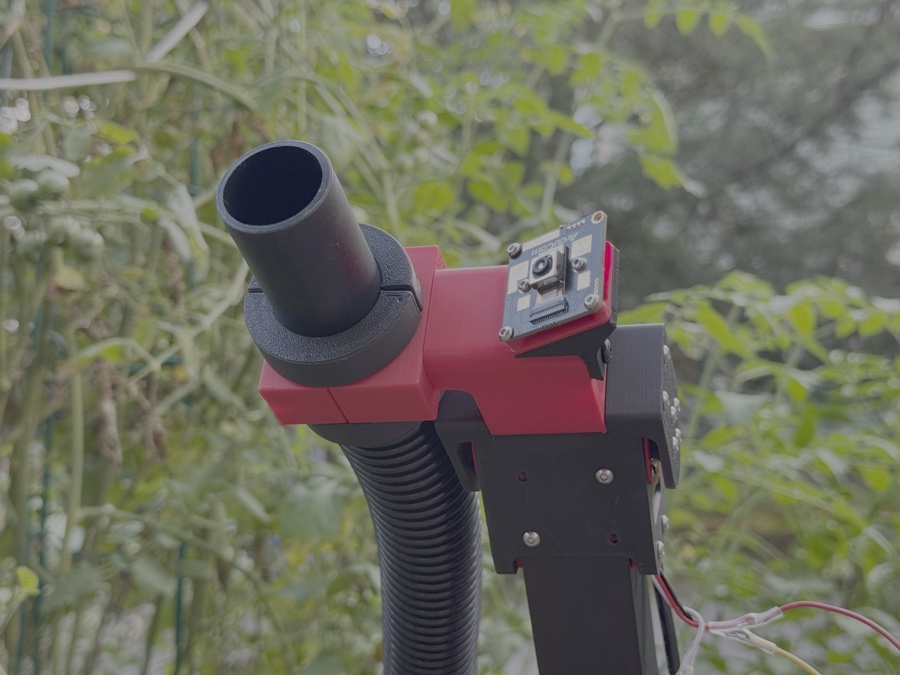
Tomato Harvester Robot
A custom 4-DOF robot arm that uses stereo vision and analytic inverse kinematics to locate cherry tomatoes and pick them with a vacuum end effector.
Robotics
Computer Vision
ROS 2
Python
Watch the demo
Mars Rover Robot
WIP submission to the University Rover Challenge 2027
Robotics
Computer Vision
ROS 2
Python
Last Updated: September 20, 2026